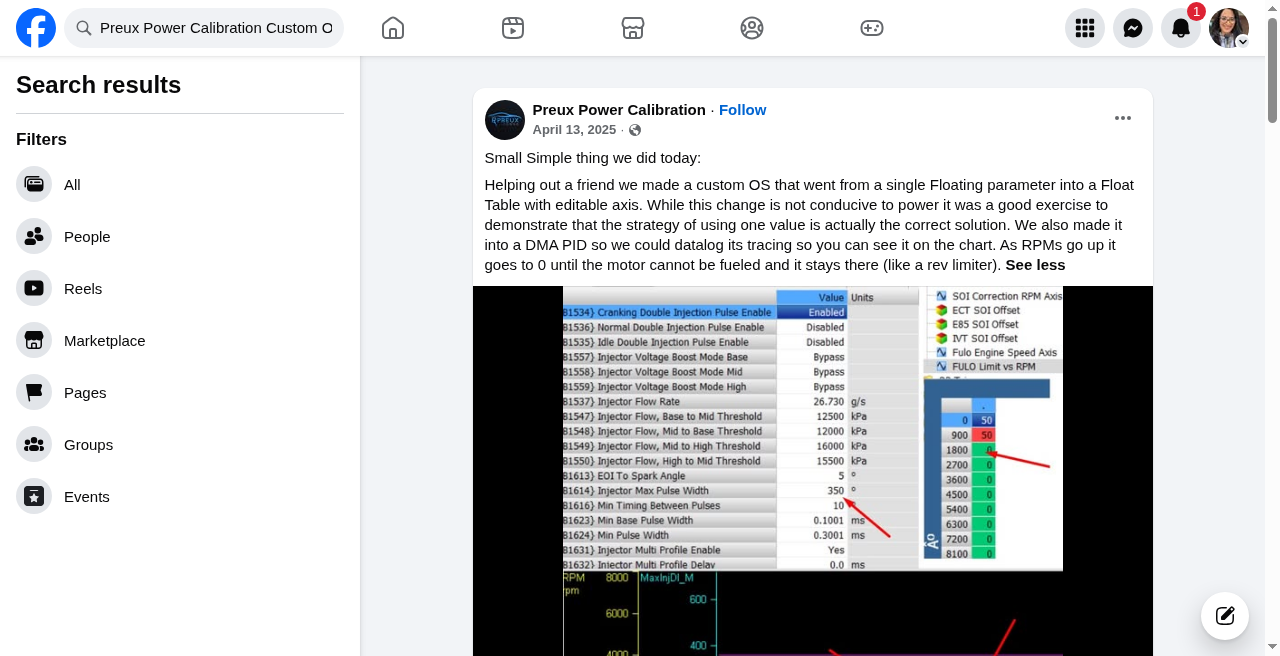
Small simple thing we did today:
Helping out a friend, we made a Custom OS that went from a single floating parameter into a float table with editable axis. That change is not about making power — it was a good exercise to show that the strategy of using one value is actually the correct solution.
We also made it into a DMA PID so we could datalog its tracing on the chart. As RPM goes up it goes to 0 until the motor cannot be fueled, then it stays there (like a rev limiter).
Originally posted on Facebook: https://www.facebook.com/photo/?fbid=122109216110823877&set=a.122103612038823877